UTS Company · Bengaluru, India

Case studies

Case studies and modules in action

Digital-twin and virtual-commissioning programmes from our team’s earlier work, and our modules in action. Client and employer names are withheld.

Enterprise programmes

Experience from large-scale digital-twin programmes

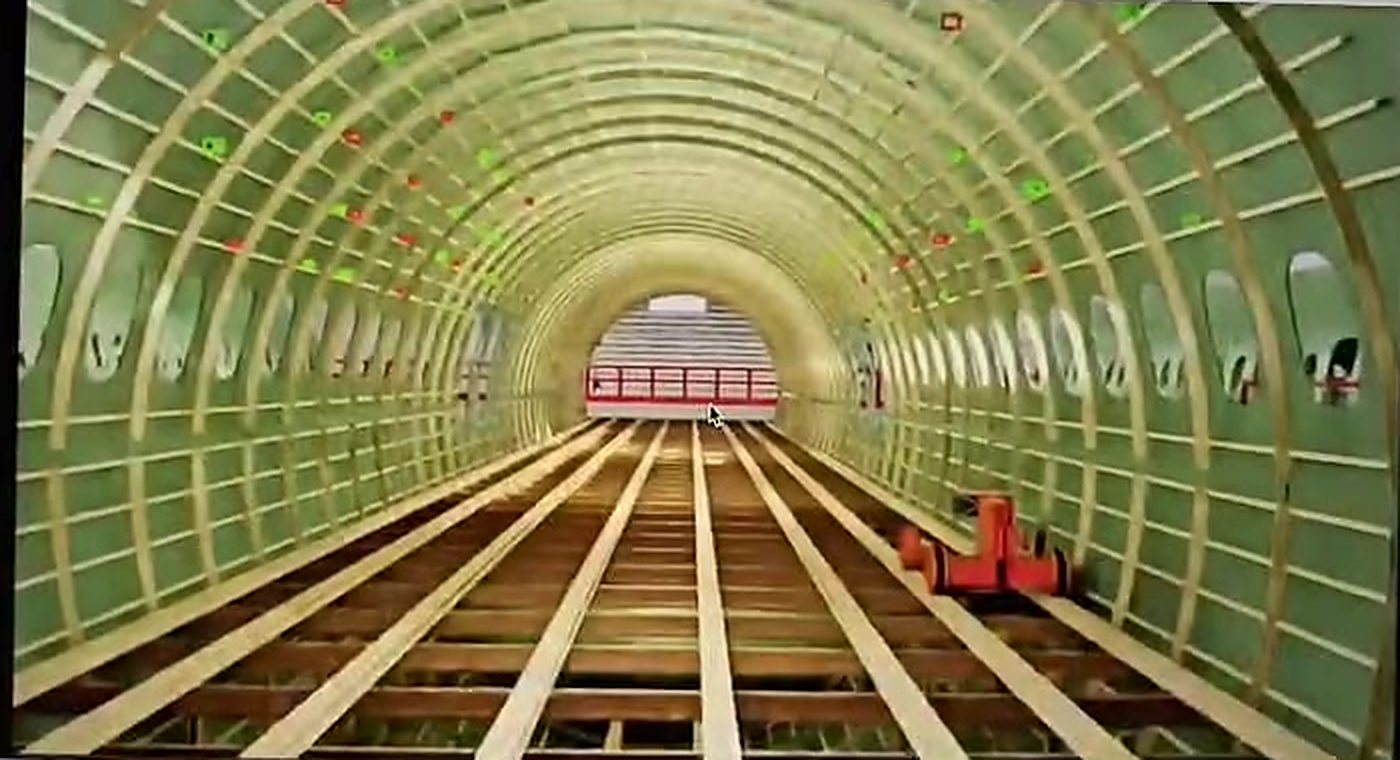
Virtual commissioning of an aircraft-fuselage inspection cellAerospace · Digital twin

Virtual commissioning of an aircraft-fuselage inspection cell

Objective. Prove a robotic scanning process for a full aircraft fuselage in a physics-accurate digital twin before any hardware was commissioned.

Outcomes achieved

  • Hangar scene and fuselage represented in a real-time 3D simulation environment
  • A custom robot with LiDAR simulated scanning the main deck and cargo area
  • Scan plan established: 20 scans cover an entire fuselage
  • Virtual commissioning simulated the process end to end and accelerated delivery
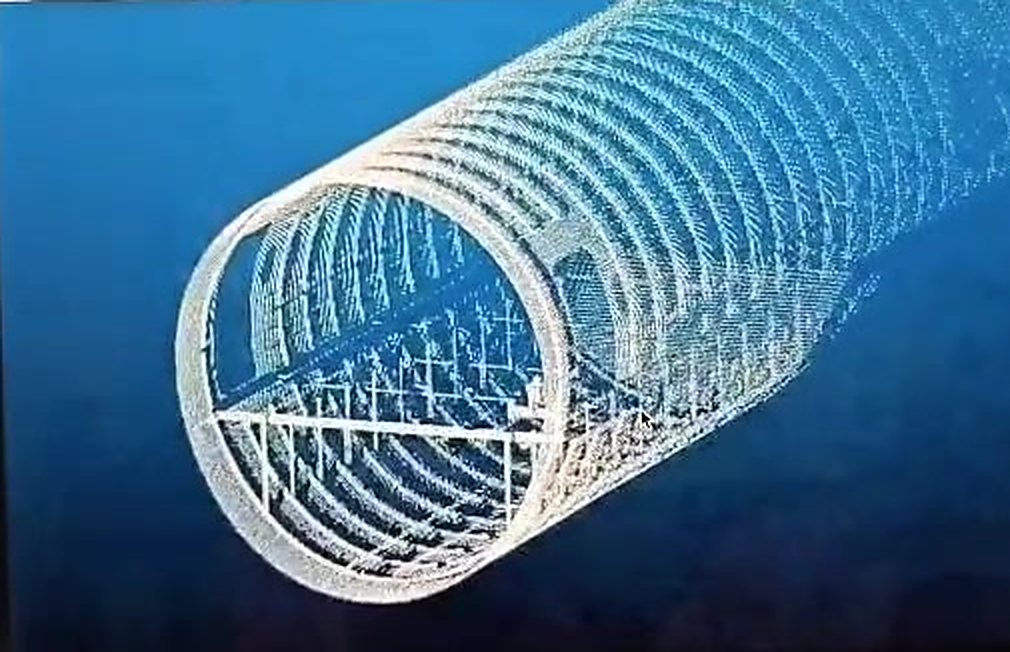
Simulated point-cloud acquisition for digital qualityAerospace · Quality

Simulated point-cloud acquisition for digital quality

Objective. Replicate real scanning conditions in simulation so that inspection algorithms could be developed and validated ahead of the physical rollout.

Outcomes achieved

  • Point-cloud acquisition simulated as in reality, with no aircraft tied up
  • Aircraft twin creation from scans, compared with a reference to classify gaps
  • Non-conformance probability and reports surfaced in a business application with 3D visualisation
  • Quality teams in multiple countries collaborating on one shared twin
Autonomous scanning robot: motion and collision-safety designAerospace · Robotics

Autonomous scanning robot: motion and collision-safety design

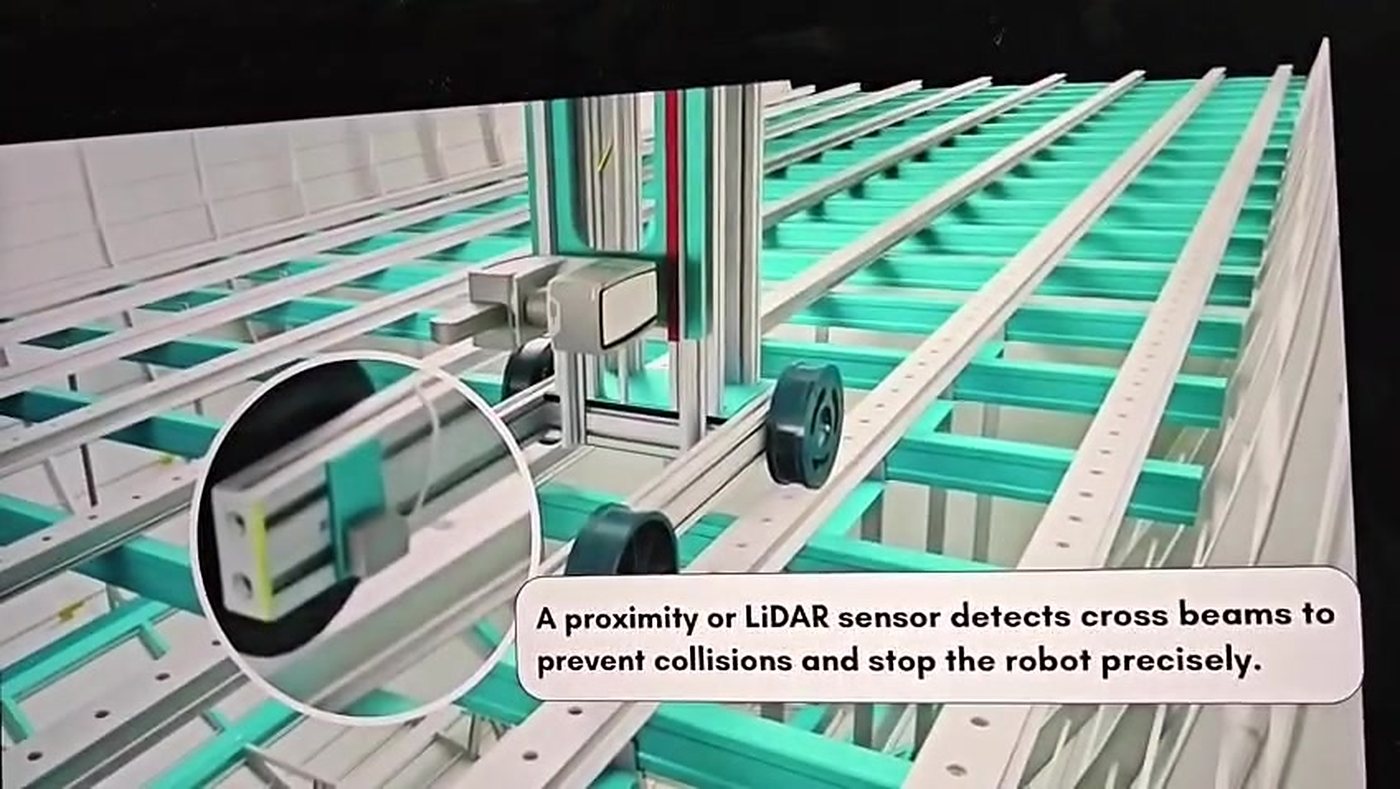
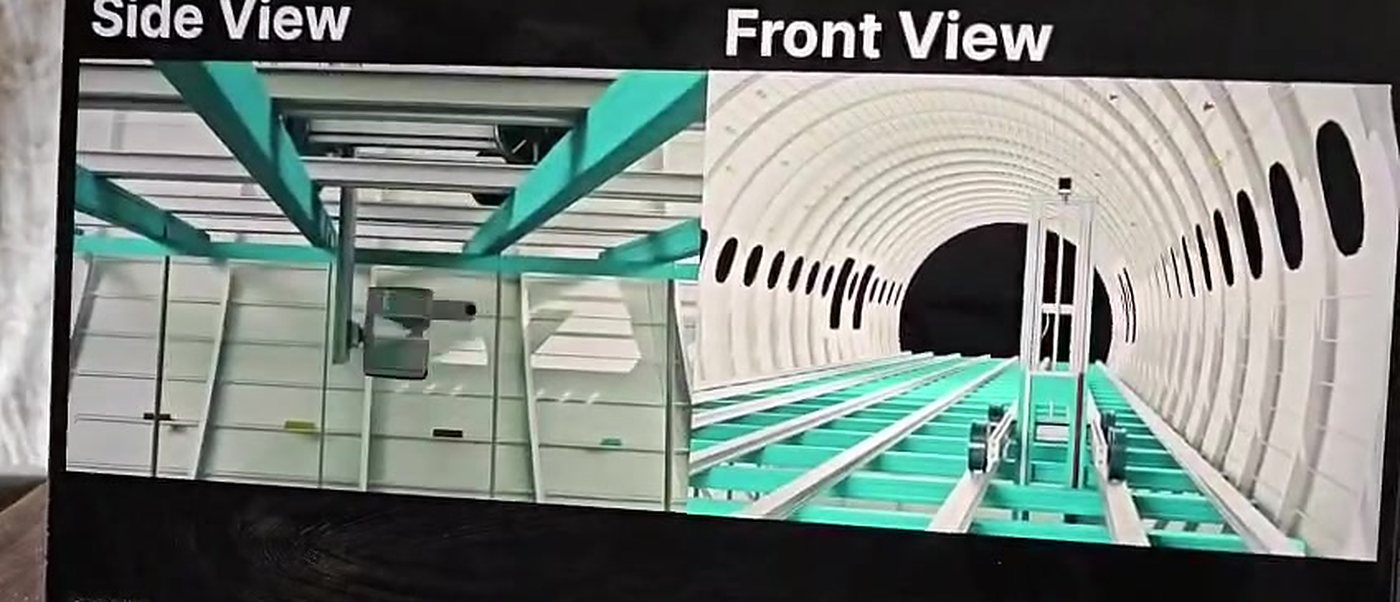
Objective. Validate how a scanning robot moves position to position through the fuselage structure and stops precisely without collisions.

Outcomes achieved

  • Full scan sequence from home position, through remaining positions, and back, simulated in side and front views
  • Proximity / LiDAR sensing of cross beams verified to stop the robot precisely
  • Passenger and cargo areas both covered by the same process
  • Real-time rendering at over 100 frames per second on a laptop GPU
A closed loop for quality: from inspection data to root causeAerospace · Digital thread

A closed loop for quality: from inspection data to root cause

Objective. Connect inspection findings to engineering and manufacturing so non-conformances are prevented, not just recorded.

Outcomes achieved

  • Feedback loops from manufacturing to engineering to prevent repeat defects
  • Non-conformance data analytics used to identify root causes
  • End-to-end continuity of the quality process from the shop floor to the customer
  • A single quality data backbone shared by quality experts and analysts

Open Netrikkan modules in action

Open Netrikkan modules, illustrated on demonstration data

Validating a tablet-line configuration before the floorPharma · Open Netrikkan

Validating a tablet-line configuration before the floor

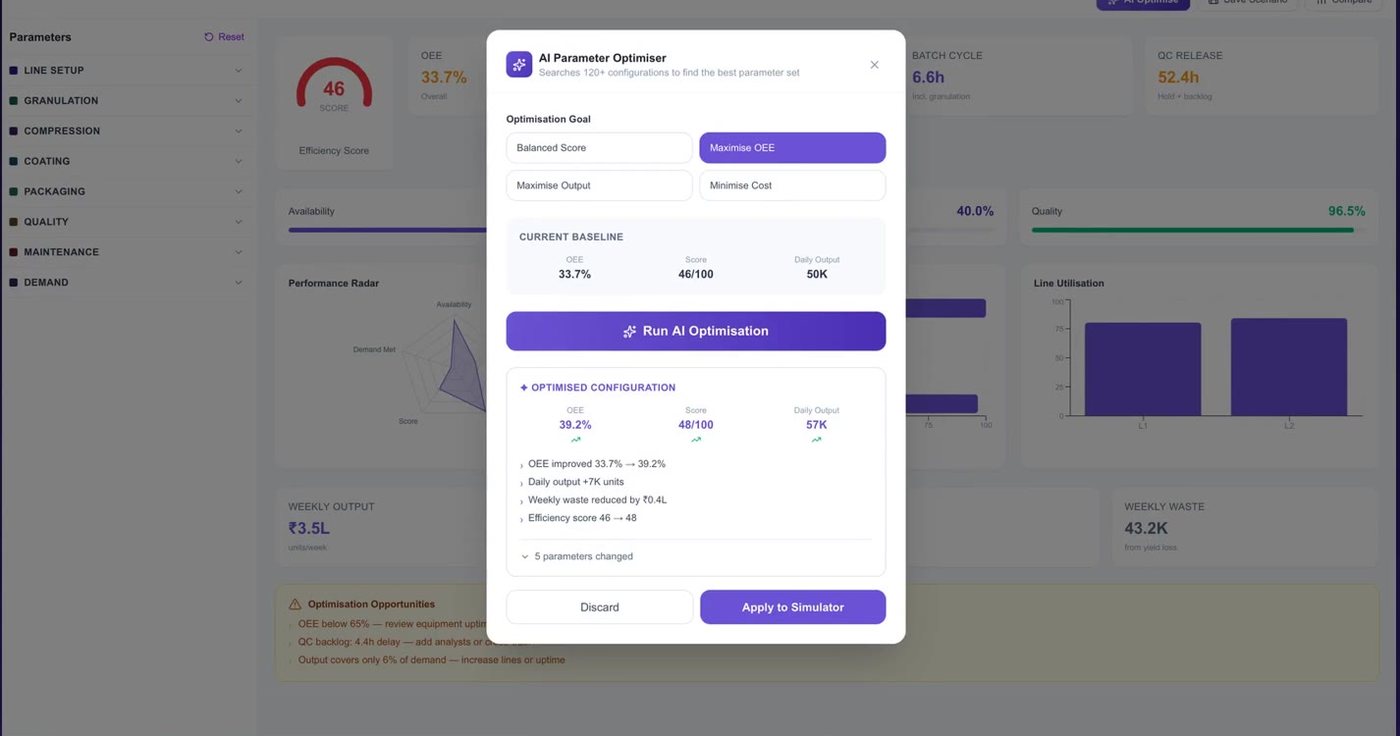
Objective. Find a better line configuration without running a trial batch — the batch that would otherwise cost more than most improvement projects.

Outcomes achieved

  • Scenario simulator with OEE, output, batch cycle and release metrics
  • AI parameter search improved demonstration OEE from 33.7% to 39.2% (about +7K units a day)
  • DES-optimised wash sequence reduces cross-contamination risk and cleaning time
  • Every scenario is a reproducible run that can be explained to quality

Trusted and recognised

Backed by a growing ecosystem

Have a similar challenge?

A 30-minute working session: you nominate the planning decision that hurts most, and we run the closest tool against a representative case from your operation.